Seekr
Room scanning · iPhone
An offline spatial organizer that converts LiDAR and ARKit scans into searchable 3D room maps with structured object data and portable exports.
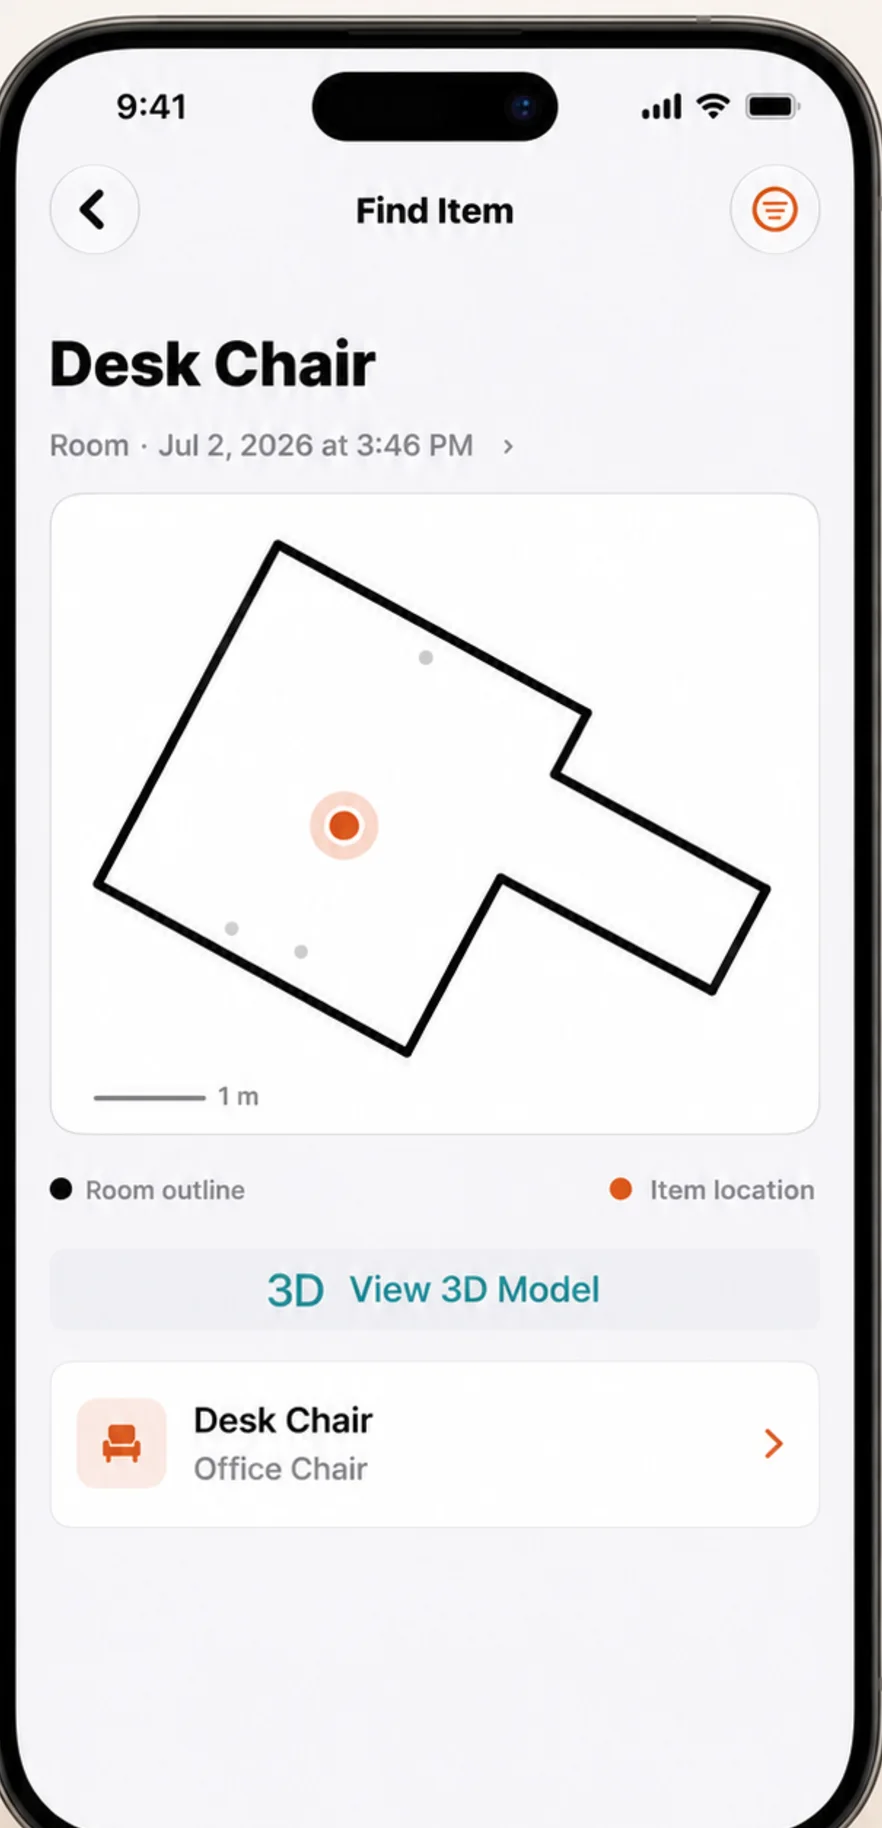
Find Item: a scanned room outline with the located object marked, and a link into the 3D model. App Store screenshot · v2.4
- Role
- Independent Software Engineer
- Timeline
- Sept. 2025 - Present
- Platform
- iOS / iPadOS
- Status
- Released
01
Overview
An offline iPhone and iPad spatial organizer that turns LiDAR and ARKit scans into searchable 3D room maps with structured object metadata and portable exports.
02
Contributions
- 01
Built semantic object search, hierarchy tags, full-text retrieval, and OBJ/PLY export around saved spatial scans.
- 02
Created a Swift-to-Objective-C++/C++ bridge that streams ARKit odometry into RTAB-Map SLAM while returning SwiftUI-safe mapping and export callbacks.
- 03
Designed hybrid persistence across Core Data metadata, canonical geometry assets, RTAB-Map databases, and disk-cache restoration.
- 04
Added encrypted peer-to-peer sharing, throttled scan updates, and explicit native resource cleanup for long sessions.
03
System design
- Tracking
- ARKit supplies device pose and LiDAR data during scanning.
- Mapping
- RTAB-Map maintains spatial state through a C++ layer connected by Objective-C++.
- Persistence
- Core Data stores searchable metadata while geometry and SLAM databases remain as canonical files.
- Sharing
- MultipeerConnectivity transfers scans directly between nearby devices without requiring a cloud account.
04
Outcome
A portable spatial data system whose scanning, indexing, persistence, restoration, and sharing workflows are designed to work offline.
Core stack
- ARKit
- RTAB-Map
- C++
- Objective-C++
- Core Data
- MultipeerConnectivity
Discuss the work
Need implementation detail or engineering context?
Email a specific question about the architecture, trade-offs, or validation approach.